-
-
-
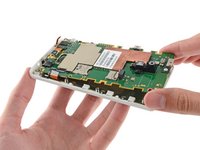
Project Tango 本质上是一个摄像头和传感器阵列,恰好运行在 Android 手机上。谷歌并没有分享除摄像头阵列之外的太多规格,但我们挖掘出了一些额外信息:
-
Snapdragon 800 四核(最高 2.3 GHz 单核频率)CPU,配备 2 GB LPDDR3 RAM
-
64 GB 内部存储空间,可通过 microSD 扩展
-
5 英寸 LCD 屏幕
-
9 轴加速度计/陀螺仪/指南针
-
当然,还有深度感知阵列:一个红外投影仪、400 万像素后置摄像头(RGB/IR)以及 180° 视场角的后置鱼眼摄像头
 询问修复机器人
-
-
-
-
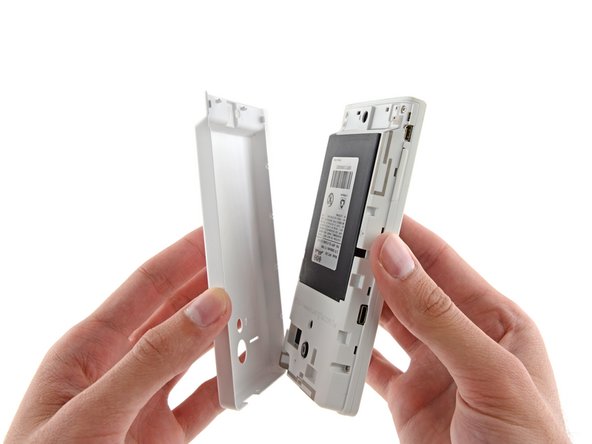
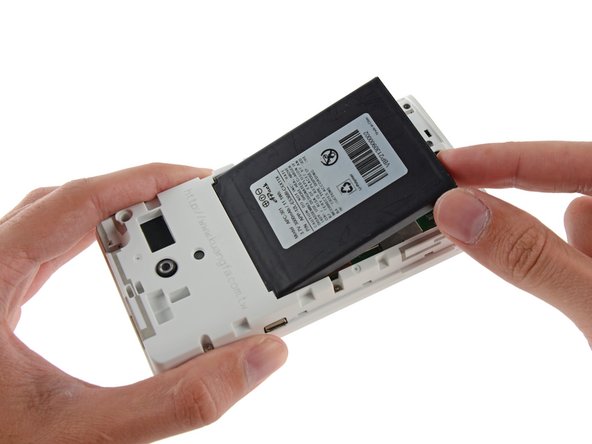
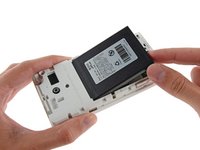
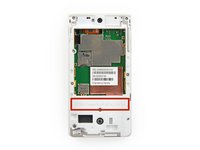
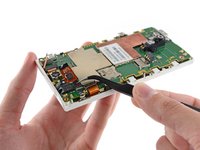
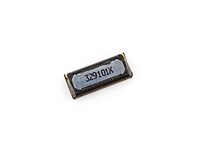
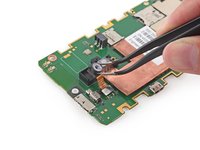
我们从轻微的粘合剂中取下听筒扬声器,这些粘合剂将其与压力触点保持接触。
-
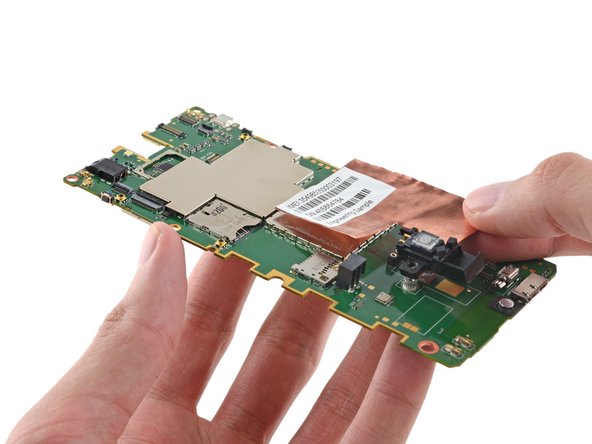
这个全新的、超定制设备上那些神秘的标记依然让我们难以捉摸。我们的搜索结果一无所获。
-
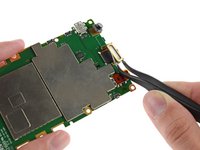
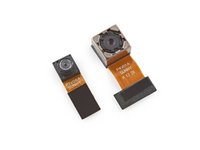
接下来登场的是两枚诱人的摄像头,以“SUNNY”(晴天/太阳)之姿向上。
-
自拍摄像头的视野(FOV)为 120º,这类似于(具有深度感知能力的)人眼视野。
-
所以我们要说的是,当你自拍时,它也在凝视你。
-
Tango 的“标准”手机摄像头是一个 400 万像素的 OmniVision 双重打击RGB 和红外摄像头传感器,它既支持高分辨率照片和视频拍摄,又能实现深度感知。
-
-
-
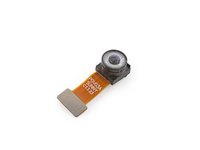
又有一个掉进尘土里了。或者说是掉进诱饵里了。这枚鱼眼镜头覆盖着一个低功耗的 OmniVision 图像传感器。
-
鱼眼镜头实现了 180° 的视野,而传感器则平衡了分辨率与帧率,以记录用于运动追踪的黑白图像。
-
-
-
Google 不希望我们开启设备,所以我们必须自己想办法 启动 红外投影仪。
-
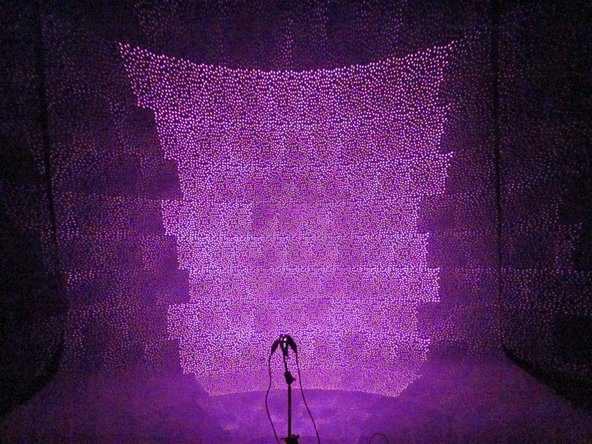
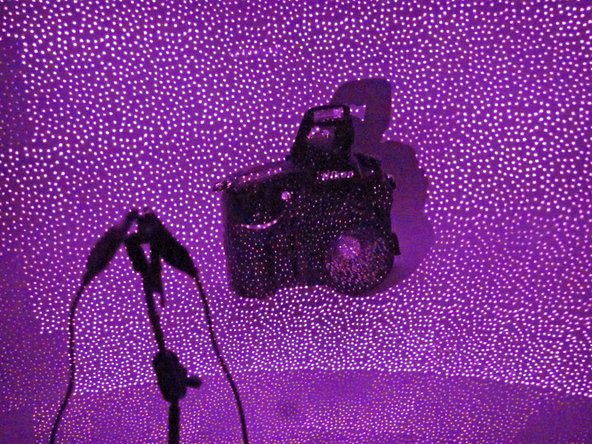
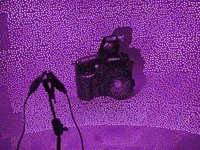
施加一点温和的电力,再加上一台 自制改装的红外摄像头,瞧!照片室墙上出现了闪亮的光点!
-
明亮的光点阵列表明,Tango 的工作原理与最初的 Microsoft Kinect 相似,都是通过投影光点阵列,并被 400 万像素摄像头的红外传感器捕捉,从而构建出深度图。
-
-
-
-
哇,慢着,这是什么?我们在 Tango 中发现了一些意想不到的新技术。
-
这看起来是 PrimeSense 最新的 Capri PS1200 SoC 3D 成像芯片,这出乎意料的原因有二:
-
就在去年,苹果收购了 Kinect 3D 视觉硬件的制造商 PrimeSense。外界推测我们会在即将推出的 iOS 设备中看到这款热门新硬件,其意图在于 进行 3D 空间测绘。看起来 Tango 是抢在苹果前面用上了自家的技术?
-
同样有趣的是,作为 PrimeSense 3D 视觉王座的超低功耗继任者,Movidius 最近一直备受 媒体关注,它终于为移动设备提供了一种解决方案。那么,PrimeSense 在这里与 Movidius 同时出现又是为了什么呢?
-
-













4指南评论
"How do you build the depth map? It certainly looks to us like nearer dots are smaller, and farther dots are more expanded. Measure the size of the dot, and you've got its distance from the projector."
This doesn't make sense, since from the point of view of the camera, the dots will appear the same size (perspective).
http://en.wikipedia.org/wiki/Binocular_d...
If you have two images of the same subject from two vantage points you can calculate roughly the depth of the image. In this case it's slightly different since once of the "cameras" is actually a projector. So one viewpoint has a "perfect" image since it has the pattern hardcoded into its frame. You just need a camera then to record the projected image and extract a disparity map between the two. From that you can determine depth.
Project Tango is a nice idea, but needing a different device is a limiting factor for mass adoption. LazeeEye empowers existing smartphones to capture 3D images by using a laser illuminator hardware add-on and a stereo vision processing app. Check out the Kickstarter Campaign https://www.kickstarter.com/projects/332...
Hi guys,
Thanks for this helpful post.
There is a LED beside the standard camera, but it is not possible to use it. You can't either somehow access the flash light or take a normal picture with flash light on. Do you guys have any idea how to possibly use the flash light? Is there a way to turn it on?
raysabzevari - 回复 分享


